Advised by Prof. Chen Feng, working on dexterous manipulation and object navigation.
I am an undergraduate at Xingjian College, Tsinghua University, pursuing a dual degree in Mechanics and Interdisciplinary Engineering. Currently, I am a research assistant at NYU AI4CE Lab, advised by Prof. Chen Feng.
My research interests center on learning-based approaches to robotics. At NYU, I work on dexterous manipulation and object navigation. Previously, at Tsinghua, I worked with Prof. Jiangtao Gong on an LLM-based autonomous-driving evaluation framework.
Outside of research, I enjoy playing basketball 🏀 and singing 🎤.
Advised by Prof. Chen Feng, working on dexterous manipulation and object navigation.
Advised by Prof. Jiangtao Gong, working on an LLM-based autonomous-driving evaluation framework.
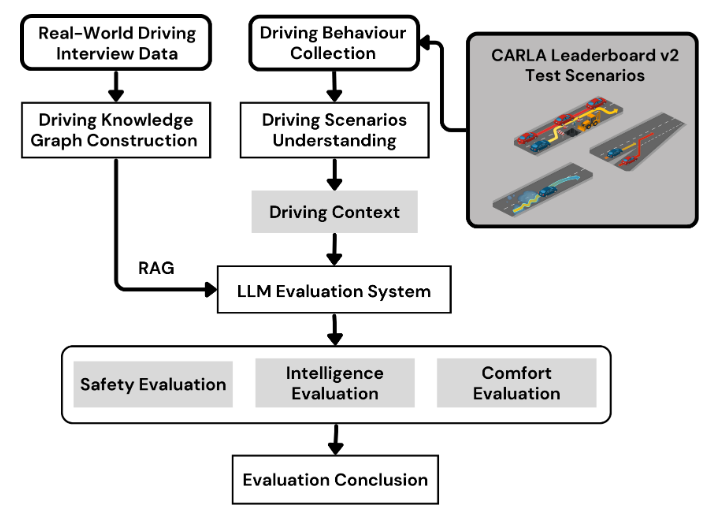
We propose a hierarchical evaluation framework for autonomous driving systems using large language models (LLMs). The framework integrates multi-modal perception, chain-of-thought reasoning, and human evaluation to assess driving behavior across operational, tactical, and strategic levels. Experiments on CARLA Leaderboard demonstrate strong alignment with human judgment.